AI / Machine Learning Engineer · Paris, France

I build vision and robotics systems, then measure where they fail.

M.Sc. Computer Vision & Robotics (ViBOT), based in Paris. I build practical AI systems, from research and experimentation through to deployment, and I care about measuring them honestly: held-out test sets, baselines, and a clear note on where each one fails.

Projects
12
Browser demos
5

Selected work

Each result, with its main limitation.

Try them

Models that run in your browser.

These demos download a quantised ONNX model and run it on your device with onnxruntime-web, so there is no inference server behind them.

  1. Construction safety monitor PPE check on worker photos with a 3.3 MB INT8 model
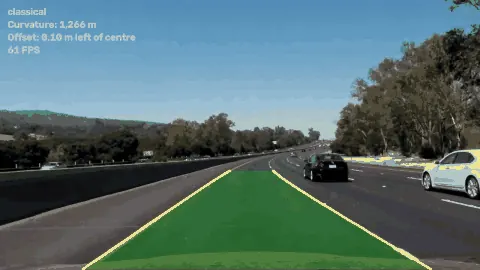
  2. Lane detection, classical vs deep U-Net and lane fit running on your own device
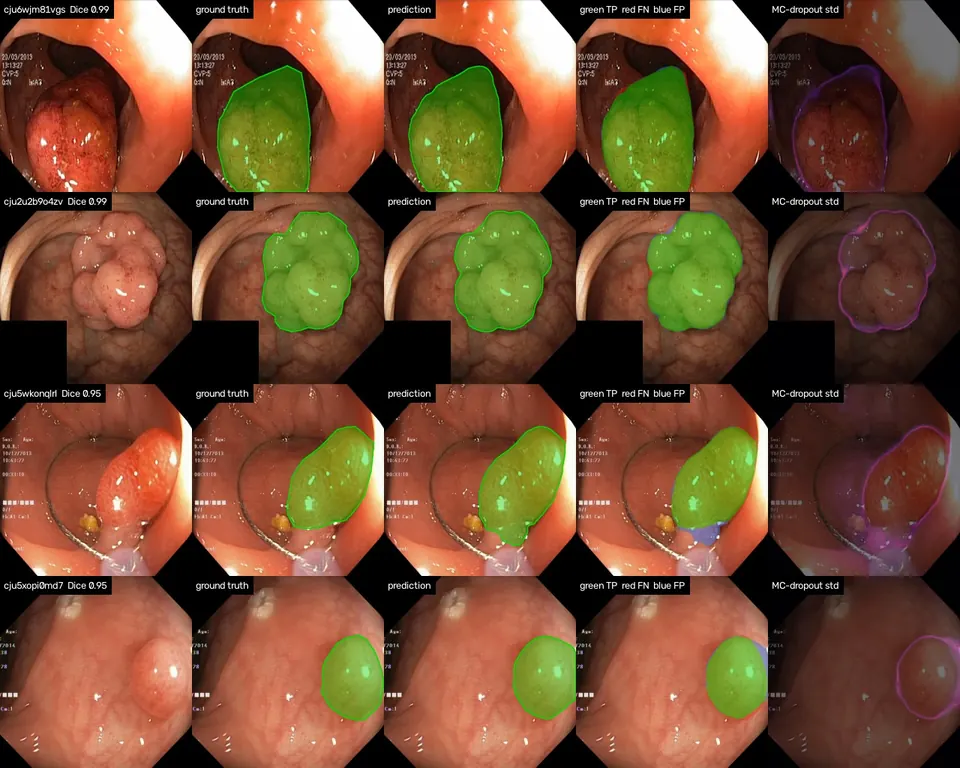
  3. Polyp segmentation Segmentation with a live uncertainty map
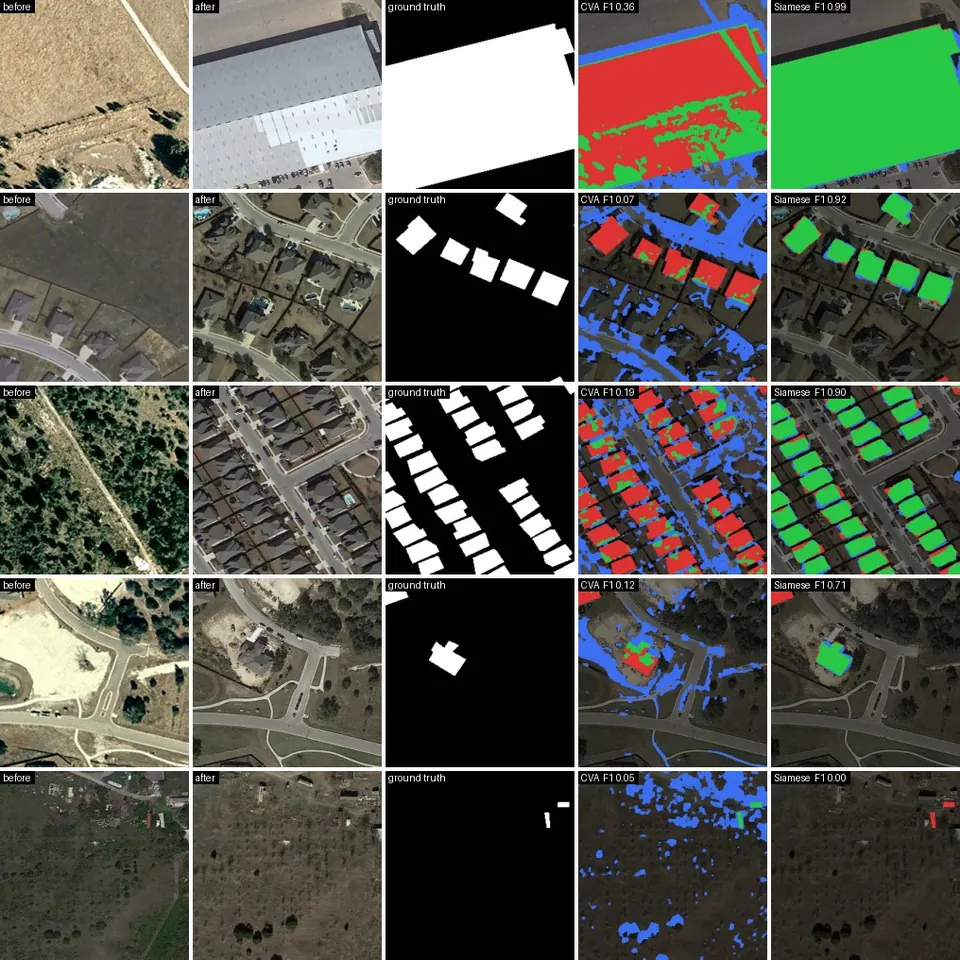
  4. Satellite land use and change 13-band land use and building change detection
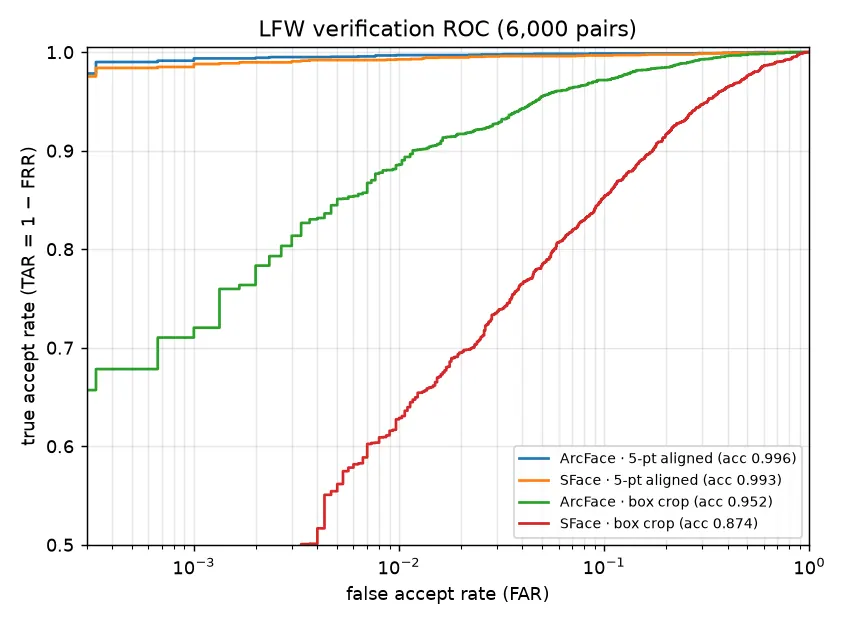
  5. Face recognition and anti-spoofing Anti-spoofing on your own webcam

About

How I work.

Each project here is its own repository with tests, CI, a reproducible pipeline and a results section. Every card shows the headline number next to its main limitation, because the limitation is usually the more useful thing to know.

Languages
Python · SQL · C++ · JavaScript
ML and vision
PyTorch · Scikit-learn · OpenCV · Transformers · Ultralytics YOLO · Open3D
Generative AI
LLMs · RAG · Embeddings · Vector databases · Agentic workflows · Voice agents
Backend
FastAPI · Flask · REST APIs
MLOps and cloud
Docker · GitHub Actions · MLflow · AWS