Computer vision
Multi-object tracking
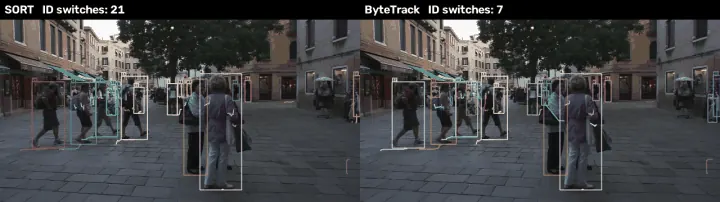
Tracks pedestrians with persistent IDs: YOLO11x detections, my own Kalman filter and Hungarian matching, and SORT against ByteTrack on MOT17.
The problem
A multi-object tracker has to keep the same ID on each person from frame to frame, through crowds and occlusions. ByteTrack's idea is to also match low-confidence detections instead of throwing them away. I wanted to measure what that alone is worth against SORT, with everything else held fixed.
What I built
- Detected people in every MOT17 frame with a COCO-pretrained YOLO11x and cached the boxes, so both trackers see identical input.
- Wrote one constant-velocity Kalman filter and one Hungarian matcher, and built SORT and ByteTrack on top, so the only difference is the association logic.
- Tuned each tracker on the first half of every training sequence and scored the second half with TrackEval.
- Broke the errors down by visibility, box size and crowding, and separated direct ID swaps from identities lost during occlusion.
Results
| Tracker | HOTA | MOTA | IDF1 | ID switches |
|---|---|---|---|---|
| SORT, paper defaults | 43.9 | 41.9 | 49.6 | 395 |
| SORT, tuned | 48.9 | 43.8 | 56.4 | 512 |
| ByteTrack, paper defaults | 46.5 | 41.4 | 53.8 | 144 |
| ByteTrack, tuned | 51.1 | 45.7 | 59.8 | 269 |
What the results show
- Tuned ByteTrack beats tuned SORT on all seven sequences, by 0.8 to 4.5 HOTA, with about half the ID switches.
- Both tuned trackers drop the detection threshold to 0.2. That buys recall with extra false positives, which is why tuned SORT has more ID switches than its defaults but still scores higher.
- Detection caps everything. DetA stays around 47, and the detector covers only 38.0 % of heavily occluded boxes.
- ByteTrack cuts direct swaps between neighbours from 161 to 68, but identities lost after more than 30 unmatched frames barely change (56 vs 42).
Limitations
- There are no appearance features, so a long occlusion ends in a new ID. Re-identification is the next step.
- The tuned ByteTrack thresholds sit on the lower edge of the search grid, and I haven't ablated which of its components gives most of the gain.
- Results are on MOT17 training sequences, not the official test server.
Full results, commands and figures are in the repository README.