Robotics
Visual odometry and SLAM
Estimates a hand-held camera's path from its images alone, with loop closure and pose-graph optimisation, scored against motion capture.
The problem
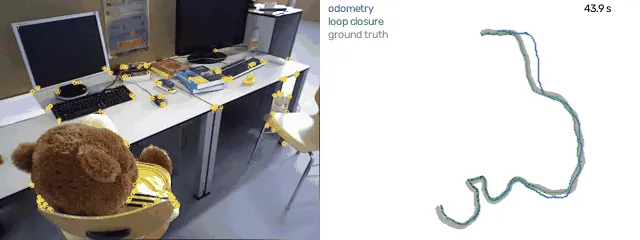
Visual odometry estimates a camera's path from its images, but every small pose error adds up and the path drifts. Loop closure recognises places seen before and pulls the path back. I wanted to measure how much it helps, and where the drift comes from in the first place.
What I built
- Tracked ORB features spread over a 4×3 grid. RGB-D mode lifts keypoints to 3D with the depth image and solves PnP against keyframes; monocular mode uses the essential matrix, triangulation and a keyframe map.
- Found loop candidates with a small bag of binary words (256 words), accepted them only after a PnP check with 60 inliers, and spread the error around each loop with a pose graph in SciPy.
- Scored every run with ATE and RPE as defined by the TUM benchmark, and checked every loop edge against ground truth.
- Binned the error by how fast the camera turned and by distance travelled.
Results
| Sequence | RGB-D odometry | + loop closure | Monocular |
|---|---|---|---|
| fr1_xyz | 4.8 | 1.4 | 10.8 |
| fr1_desk | 8.5 | 2.9 | 67.7 |
| fr1_room | 17.9 | 8.8 | 53.6 |
| fr3_long_office_household | 19.2 | 7.6 | 148.3 |
What the results show
- Loop closure cut ATE by 51–70 % on every sequence. None of the 101 accepted loop edges was a false match; each agrees with ground truth to within 5.2 cm and 3.2°.
- It fixes accumulated drift, not local error: RPE per second is almost unchanged.
- Fast rotation is the main source of error. RGB-D odometry error grows from 1.3 cm in slow windows to 4.7 cm above 40° per second, and monocular tracking is badly wrong in 88 % of the fastest windows.
- Keyframes matter: on fr3 they mean 260 reference switches instead of 2,488, and ATE drops from 57.6 to 19.2 cm.
Limitations
- Loop closure runs once after tracking, and the pose graph corrects keyframe poses only, with no full bundle adjustment.
- Monocular parameters were tuned on fr1_xyz alone, and it loses tracking under fast rotation.
- Four indoor sequences only, with no driving data and no dynamic scenes.
Full results, commands and figures are in the repository README.