Robotics
Multi-view 3D reconstruction
Photos to cameras to a mesh to a Blender render, with Structure-from-Motion written from scratch and compared with COLMAP.
The problem
Structure-from-Motion recovers camera poses and 3D points from ordinary photos, and COLMAP is the standard tool for it. I wrote the pipeline myself to see which parts are hard, then compared it with COLMAP on the same images and scored both against ETH3D's laser-aligned cameras and scans.
What I built
- Wrote relative pose estimation: a Hartley-normalised 8-point solver, RANSAC with Sampson error and a non-linear refinement. OpenCV is used only for SIFT, PnP and image I/O.
- Built incremental SfM on top (tracks, PnP, triangulation, sparse bundle adjustment in SciPy) and ran the same scenes through COLMAP with the same intrinsics.
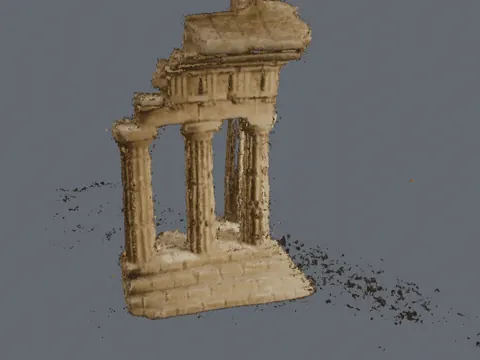
- Computed dense depth with a ZNCC plane sweep in PyTorch on the Apple GPU, fused depth maps where several views agree and meshed the result with Poisson reconstruction.
- Scripted Blender to orient the mesh from the camera positions and render a turntable.
Results
| Scene (images) | Mine: registered | Mine: median error | COLMAP: registered | COLMAP: median error |
|---|---|---|---|---|
| pipes (14) | 14 | 0.21 cm | 11 | 0.26 cm |
| meadow (15) | 6 | 3.0 cm | 14 | 4.4 cm |
| terrace (23) | 23 | 0.85 cm | 23 | 1.69 cm |
| relief (31) | 31 | 0.24 cm | 31 | 0.23 cm |
What the results show
- On the three ETH3D scenes where every camera registers, my median camera error is 0.21–0.85 cm, level with or better than COLMAP on pipes and terrace.
- On two-view pose my solver is more precise (median rotation error 0.17° against 0.65° for OpenCV's 5-point), while OpenCV's is more reliable on the hardest pairs. The refinement step is the biggest single gain.
- Dense accuracy is good but completeness varies. On relief 96 % of fused points lie within 5 cm of the laser scan, while pipes' white walls give ZNCC nothing to match.
- My SfM cameras are good enough for dense work: terrace scores F1 0.76 with them against 0.73 with the ground-truth cameras. That run also takes depth ranges from my sparse points, so it isn't a pure camera comparison.
Limitations
- COLMAP is 15 to 100 times faster. On meadow the match graph splits and mine registers 6 of 15 images against 14.
- On relief one of my cameras lands 56 cm off, which COLMAP avoids.
- My SfM assumes known intrinsics, and the dense metric is a simplified ETH3D protocol that isn't comparable with the official leaderboard.
Full results, commands and figures are in the repository README.